Your lawn slopes 15 degrees, and your robot mower keeps spinning its wheels—or worse, sliding sideways into the flower bed. Before you blame the motor or write off robotic mowing altogether, look closer at what's actually touching the ground: the wheels.
Traction on inclines comes down to a precise interplay of tread pattern, rubber compound, wheel diameter, and drive layout. That mix decides whether your mower climbs confidently or slips into a stall. Some designs handle a robot mower slope percentage limit of 20%, while others struggle past 10%.
We break down how wheel engineering translates into real-world hill-climbing ability—covering everything from spiked wheels versus rubber tires to torque distribution and chassis articulation—so you can match the right design to your terrain before you buy.
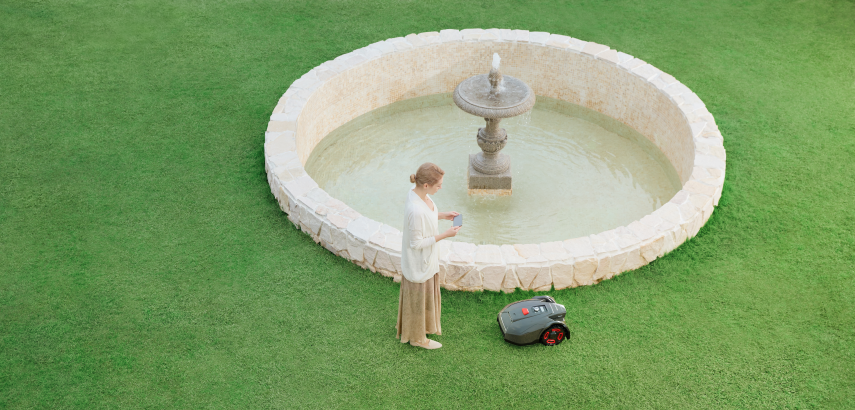
How Slope Angle Changes Robot Mower Wheel Traction
Traction doesn't fail gradually—it collapses fast once a mower approaches its rated limit. As slope angle climbs, wheels lose contact force, grass gets slicker, and side slopes or sharp turns eat into grip that looked fine on paper.
Traction Thresholds by Mower Class
Different drive systems handle different robot mower slope percentage limits:
Basic 2WD residential mowers: 15–25% slope (8°–14°)
Standard residential models: 20–30% slope (11°–17°)
Mid-range AWD models: 30–35% slope (17°–19°+)
Premium AWD/all-terrain models: 40–70% slope (22°–35°)
Extreme/track-based designs: up to 80% slope (~38°), with some track units claiming 45°/100% grade
Honda Miimo models, for reference, are rated to 47% slope—roughly 25°. Many premium units cap out around 35°–38°, or 70–80% grade.
Why Rear-Wheel-Drive Struggles First
RWD mowers push power through just two wheels. One wet patch, one camber shift, and that single wheel spins out—gouging turf instead of climbing it. An all-wheel drive robot mower spreads torque across every contact point, which is exactly why AWD models handle steeper ground with less drama.
A Practical Buying Rule
Don't buy to match your steepest slope—buy 5–10° above it. And measure the steepest section of the actual mowing path, not the yard average. A short, steep patch can trigger slip even when the rest of the lawn looks flat and manageable.
Tread Pattern and Rubber Compound for Robot Mower Grip
Wheel diameter and drive layout are only half the equation. The tread pattern and rubber compound actually contact the grass, and decide whether that force turns into forward motion or wasted spin.
Tread Patterns Ranked by Grip
Not all lawn mower wheel tread patterns perform equally on slopes.
Smooth tread: best for flat lawns; lowest bite, least turf disturbance
Turf tread / square-shouldered: balances grip with lawn protection; common in golf-course-style applications
Ribbed tread: better straight-line stability on inclines, less lateral slip
Knobby/lug tread: strongest traction on wet, muddy, uneven ground
All-terrain tread: hybrid design for mixed lawn conditions
For genuine hill-climbing, spiked wheels robot mower designs with deep lug or tractor-style profiles outperform smooth alternatives every time. The raised lugs dig into turf rather than skating across it, exactly what wet grass and uneven slopes demand.
Rubber Compound Matters More Than People Think
A flexible or natural rubber compound consistently beats hard plastic and stiff polyurethane wheels on grass. Some turf tires use a special silica compound specifically to improve grip on soft, loose, uneven ground. Replacement wheels are even being 3D printed in TPU, a flexible rubber material chosen purely for added grip.
Self-Cleaning Channels Keep Grip Consistent
Tread that packs with mud or clippings stops gripping fast. Self-cleaning groove systems eject debris mid-rotation, keeping lugs engaged instead of clogged.
The upgrade math applies. If your mower slips on slopes or wet grass, deeper lugged tread paired with softer rubber typically outperforms a wider wheel—and it's often the cheaper fix. Upgraded all-terrain wheels are now rated for slopes up to 22°, or 40% gradient, on wet grass and soft soil.
Wheel Diameter, Width, and Contact Patch on Hills
A wheel's diameter and width directly affect how much rubber touches the ground and how well that rubber grips on a slope.
Bigger Wheels Handle Rough Terrain Better
Larger wheels roll over obstacles with less effort. A 100 mm wheel clears a 10 mm lip far more smoothly than a 50 mm wheel, because the attack angle is shallower. On rocky or uneven hills, this means steadier climbing and fewer stalls. On smoother slopes, the advantage shrinks. Smaller, lighter wheels can accelerate uphill quicker in stop-start conditions.
Contact Patch Shape Changes With Diameter
At the same tire pressure, contact patch area stays roughly constant regardless of wheel size. But larger wheels form a longer, narrower footprint, while smaller wheels sink deeper into soft or uneven ground, raising rolling resistance exactly when you need traction most.
Width Adds Grip
Contact patch area is width × contact length. Wider wheels increase that footprint, boosting grip on climbs. Narrower wheels roll easier but sacrifice traction. Downhill longboard setups, built for aggressive cornering grip, use 70–80 mm wheels with a 50–56 mm contact patch.
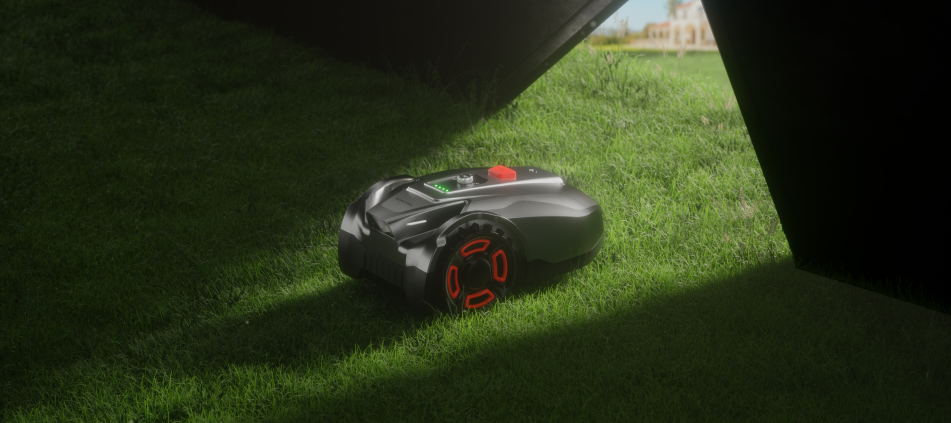
2WD, AWD, and Tracked Drive for Robot Mower Hill Climbing
Drive layout determines the limit before you even think about wheel design. Three architectures dominate the market, and each targets a different slope range.
The Three Drive Systems Compared
2WD tops out around 20°–25° slope (35%–45% grade). Fine for gentle lawns, unreliable past that ceiling. AWD/4WD reaches 35°–38° (70%–80% grade) and is the main choice for steep residential terrain. Tracked drive is the highest-performing class, with reported capability up to 45° (100% grade).
The Industry Rule of Thumb
Once slopes exceed roughly 30° or 58% grade, wheeled 2WD becomes unreliable. AWD/4WD becomes the practical minimum. Tracked drive wins on mud, loose soil, and obstacle transitions because continuous ground contact never breaks.
Above 80% grade, prioritize tracked drive. Between 60%–80% grade, high-torque AWD/4WD is the mainstream fit. Under 45% grade, standard 2WD still works fine.
Suspension, Articulated Chassis, and Robot Mower Stability on Inclines
Traction gets a mower up the hill. Suspension and chassis design decide whether it stays stable, level, and safe once it’s there. These two factors work together, but they solve different problems.
The Boundary vs. Work-Area Split
Slope ratings aren’t uniform across a lawn. Some standard Husqvarna units go further, permitting 40–50% in the work area but only 15–25% at the boundary. Edge traction is its own constraint, separate from straight-uphill climbing. If your slope’s steepest section sits near a boundary line, that’s the number that matters.
Suspension Keeps the Deck Level
Independent front suspension lets the chassis flex over bumps while the cutting deck stays level. That’s critical on uneven inclines where one wheel might be six inches higher than another.
Articulation Reduces Turn-Related Slip
Turning on a slope is where wheeled mowers most often lose grip. One side has to slow or reverse while the other advances. True AWD and articulated chassis designs manage this lateral force better than rigid 2WD frames, cutting slip during rotation rather than during straight climbs.
Top-End Benchmarks
At the premium tier, the Mammotion LUBA 3 AWD, Segway Navimow X4 series, and MOVA LiDAX Ultra AWD all cluster around 80% grade (38.6°). That’s currently the practical ceiling for mainstream consumer units.
Every Mower Has a Safety Ceiling
Regardless of drive system, every robot mower includes a tilt sensor that cuts blade and drive power once chassis angle exceeds a preset limit. Real-world slope performance always sits below the absolute rollover threshold. So a spec sheet’s “max grade” is a working limit, not an emergency cutoff.
Wheel Torque, Weight Distribution, and Motor Power on Slopes
The physics of wheel torque on robot mowers comes down to one equation: F_wheel = mg[sin(θ) + Cr(v)cos(θ)] + ½ρCdAv². Gravity, rolling resistance, and air drag all pull against the motor once the ground tilts.
Slope Force Jumps Fast
Going from flat ground to a 5° incline increases required force by 6.8×. One AGV benchmark for a 500 kg unit calculated slope force at roughly 427 N on a 5° grade, with total force hitting 500.6 N. That translated to 27.8 Nm per motor across two driven wheels, running at about 90% drivetrain efficiency. A separate sizing template showed a 35 lb vehicle on just a 2° incline generating 1.2 lb of grade resistance—small angles, real load.
Why Torque Alone Isn't Enough
Wheel torque converts to tractive force through T_w = TTE × R_w × RF, but there's a cap at the maximum tractive torque before slip: MTT = W_w × μ × R_w. Push motor torque past that road-friction limit, and the wheel spins instead of climbing, regardless of horsepower.
Weight Distribution Decides What's Available
Only load sitting on driven wheels contributes to traction. Climbing a slope shifts weight rearward, changing front/rear normal forces instantly. Wheeled robotics benchmarks report distributions like 180 lbf across six wheels versus 275 lbf across four. Fewer contact points concentrate load differently, directly affecting slip prevention on grade.
For anyone comparing specs, the inputs that matter are mass, incline angle, wheel radius, rolling resistance, drag coefficient, drivetrain efficiency, gear ratio, and driven-wheel count.
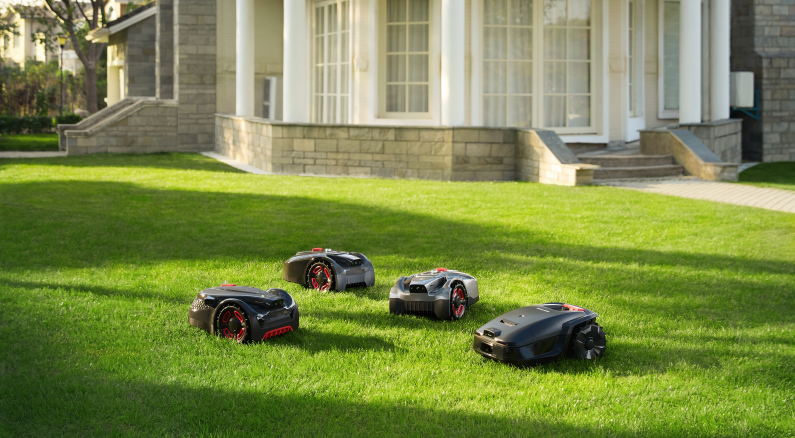
Slope Capability Comparison of Leading Robot Mower Designs
Spec sheets rarely agree on units. One brand lists degrees, another lists grade percentage, and shoppers are left guessing which number actually matters. Here's the quick conversion: 45% ≈ 24°, 70% ≈ 35°, 80% ≈ 38.6°, and 100% = 45°. Keep that scale handy while comparing published ratings across brands.
Sourcing Filter by Grade Range
Use these benchmarks when filtering spec sheets:
Below 40% grade: basic residential hills, 2WD sufficient
45–50% grade: entry point for stronger hillside coverage
70% grade: key premium AWD benchmark
80% grade: strongest widely cited mainstream AWD ceiling
100% / 45°: reserved for tracked systems only
Match your steepest measured section against this table before comparing prices—grade rating should be the first filter, not the last.
Wheel Design Requirements by Slope Range
Engineering standards outside the mower industry offer a useful framework here. Vehicle gradeability research consistently breaks slope handling into distinct bands, and each band demands a different wheel approach.
Low-Grade Zones Need Basic Geometry Only
0–5% slope: standard wheel geometry handles this fine. Drainage, camber, and rolling resistance matter more than raw grip. 5–8% slope: this starts behaving like a ramp. Braking stability and wheel-path control become the priority, not just forward traction.
Mid-Range Slopes Demand Purpose-Built Traction
8–20% slope is where robot mower wheel design gets serious. Slope capability becomes a primary sizing requirement, not an afterthought. NASA's rover design work offers a telling benchmark: wheels sized to handle a 20° slope while maintaining positive drawbar pull, including starts and stops at 1 m/s on that grade.
Steep Grades Shift the Engineering Priority
20–60% grade pushes design into high-traction territory. Torque output, weight transfer, and brake-holding capacity dominate over tread pattern alone. Military vehicle specs require negotiating a 60% grade in both forward and reverse, plus adequate braking—useful context when evaluating any robot mower slope percentage limit claim above 50%. Side-slope testing at 20–40% adds another layer most spec sheets skip entirely.
Boundary Layout and Slip Prevention on Steep Lawns
Boundary layout and wheel design each handle half of the slip challenge. Even a mower rated for steep grades can slip if the mowing path is poorly mapped.
Map the Slope Before Setting Boundaries
Use an inclinometer to identify slope breaks before drawing cut lines. Keep boundaries away from crest edges, drainage transitions, and grade-change points. At those spots, traction shifts abruptly and turns destabilize fastest.
Lane Direction Beats Diagonal Routing
Split steep terrain into short, straight horizontal lanes instead of long diagonal paths. Diagonal routing increases sideways slip risk. Break uneven sections into smaller zones, and reserve the steepest patch for a lighter-duty pass.
Wet Grass Cuts Your Margin
Wet turf raises slip risk sharply. Reduce usable slope limits by roughly 5° in wet conditions, a real-world buffer worth building into any boundary plan.
Wheel Design Inspection Checklist for Hilly-Lawn Purchases
A spec sheet only tells half the story. Before you check out, give the wheels the same physical once-over a commercial mowing technician would.
Pre-Purchase Wheel Checks
Tire pressure: Confirm it matches the manufacturer's specs.
Wear pattern/damage: Uneven wear means you're looking at alignment or bearing trouble.
Valve stem and wheel condition: Cracks here fail fast under slope load.
Wheel bolts, bearings, and arms: Tight bolts and smooth bearings keep the wobble off inclines.
Wheel nut tension: Loose nuts amplify the slip risk on a grade.
Sizing and Fit Verification
Match the sidewall size, axle diameter, hub width, and rim diameter exactly. Common axle sizes are 1/2 in and 5/8 in, and a wrong fit will undo any tread advantage. For hilly terrain, lean toward wider-profile, larger-diameter wheels, and double-check the mower's rated slope limit before you commit.
Conclusion
Traction on a slope is physics. The wheel design that keeps a mower planted depends on three things: tread depth and rubber compound gripping the turf, torque distribution across all-wheel drive or tracked systems, and a low center of gravity that resists tipping. Get any of these wrong, and even a powerful motor won’t stop wheel slip on wet or steep terrain.
Before you buy, walk your lawn and measure its steepest section. Match that number against a mower’s published robot mower slope percentage limit, then check whether its wheel design—spiked, ribbed, or all-wheel drive—actually supports that rating rather than just approaching it.
Use the inspection checklist above as your final filter. A mower that handles your slope confidently today will save you from replaced boundary wire, scarred turf, and frustrated resets tomorrow. Choose the wheels built for your terrain, not just the spec sheet.